
Learning objectives / 学习目标
完成本课后,你应能:
- 区分 three-force、four-force、coordinate acceleration、four-acceleration 与 proper acceleration。
- 推导 \(K^\mu=\gamma(\mathbf F\cdot\mathbf u/c,\mathbf F)\) 及 \(K\cdot U=0\),并分析平行/垂直加速度响应。
- 从 Lorentz scalar proper time 构造自由 massive particle action,说明自由世界线为何是 stationary straight worldline。
- 由 \(L=-mc^2\sqrt{1-u^2/c^2}\) 得 canonical momentum 与 \(H=\sqrt{p^2c^2+m^2c^4}\)。
- 正确处理 \(m=0\) 的 mass shell、速度和 frame 边界,解释为何不能直接令 massive proper-time action 中 \(m=0\) 来获得完整动力学。
Prerequisites / 先修知识
- Four-Vectors:\(U^2=c^2\)、\(p^\mu=mU^\mu\)、boost 与 scalar product。
- Energy, Momentum, and Reactions:\(E^2=p^2c^2+m^2c^4\)。
- 经典 Lagrangian、Euler–Lagrange equation、canonical momentum 与 Hamiltonian 的基本定义。
Scope and conventions / 范围与约定
- 平直 Minkowski spacetime,度规 \(\eta=\operatorname{diag}(1,-1,-1,-1)\)。
- \(x^\mu=(ct,\mathbf x)\),\(U^\mu=\gamma(c,\mathbf u)\),\(p^\mu=(E/c,\mathbf p)\);\(m\) 是 invariant mass。
- three-force 定义为同一 inertial frame 中
\[\mathbf F=\frac{d\mathbf p}{dt},\]
而不是预先假定 \(m\mathbf a\)。
- three-acceleration 是 \(\mathbf a=d\mathbf u/dt\);four-acceleration 是 \(A^\mu=dU^\mu/d\tau\);proper acceleration 大小为 \(\alpha=\sqrt{-A^\mu A_\mu}\)。
- 作用量只比较固定端点之间允许的 timelike worldlines;物理路径使作用量 stationary。直线 worldline 在平直时空使 proper time 最大,而 \(S=-mc^2\int d\tau\) 相应取最小,但“stationary”是最稳妥表述。
- 自由粒子章节不加入 potential。电磁耦合 \(qA_\mu dx^\mu\) 留给下一 Unit。
- massless particle 采用 \(p^2=0\) 与 \(E=pc\) 的运动学;更完整的 reparameterization-invariant null action 只作边界说明。
Notation and modeling contract / 符号与建模契约
| Symbol | Meaning | SI unit |
|---|---|---|
| \(\mathbf u\) | three-velocity in a stated inertial frame | \(\mathrm{m\,s^{-1}}\) |
| \(\mathbf a\) | coordinate three-acceleration \(d\mathbf u/dt\) | \(\mathrm{m\,s^{-2}}\) |
| \(\mathbf F\) | three-force \(d\mathbf p/dt\) | N |
| \(A^\mu\) | four-acceleration \(dU^\mu/d\tau\) | \(\mathrm{m\,s^{-2}}\) |
| \(K^\mu\) | four-force \(dp^\mu/d\tau\) | N |
| \(\alpha\) | proper acceleration magnitude | \(\mathrm{m\,s^{-2}}\) |
| \(S\) | action | \(\mathrm{J\,s}\) |
| \(L\) | coordinate-time Lagrangian | J |
| \(\mathbf p_{can}\) | canonical momentum | \(\mathrm{kg\,m\,s^{-1}}\) |
| \(H\) | Hamiltonian / free-particle total energy | J |
| \(\lambda\) | generic affine worldline parameter | chosen by convention |
为避免与 four-force \(K^\mu\) 混淆,本课 kinetic energy 需要时写 \(T\) 或明确写“kinetic energy”;四维力固定记作 \(K^\mu\)。
Knowledge 1 — Four-force and relativistic acceleration / 四维力与相对论加速度
Knowledge ID: P06-U03-L03-K01
四维定义与三维投影
对 invariant mass 恒定的 particle,定义
\[K^\mu=\frac{dp^\mu}{d\tau}=m\frac{dU^\mu}{d\tau}=mA^\mu.\]
由于 \(d/d\tau=\gamma d/dt\),且功率定理为
\[\frac{dE}{dt}=\mathbf F\mathbin{\cdot}\mathbf u,\]
得到
\[\boxed{K^\mu =\gamma\left(\frac{\mathbf F\mathbin{\cdot}\mathbf u}{c},\mathbf F\right)}.\]
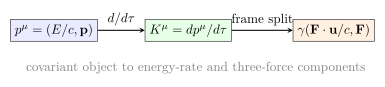
四速度 norm 恒定:
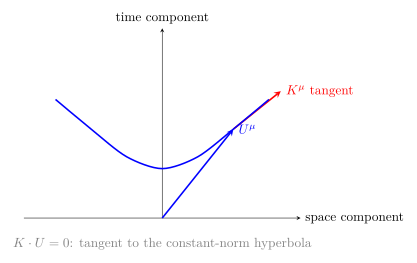
\[\frac{d}{d\tau}(U^\mu U_\mu)=2A^\mu U_\mu=0.\]
故
\[\boxed{A\mathbin{\cdot}U=0}, \qquad \boxed{K\mathbin{\cdot}U=0}.\]
这里的“正交”是 Minkowski 正交,不是说在普通三维空间里 \(\mathbf F\perp\mathbf u\)。当 \(\mathbf F\parallel\mathbf u\) 时,\(K^0\) 反而非零,因为能量正在变化。
three-force 与 coordinate acceleration
从 \(\mathbf p=\gamma m\mathbf u\) 求导:
\[\mathbf F =m\left[\gamma\mathbf a +\gamma^3\frac{\mathbf u\mathbin{\cdot}\mathbf a}{c^2}\mathbf u\right].\]
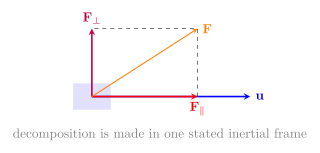
把 \(\mathbf a\) 分成平行与垂直于 \(\mathbf u\) 的分量:
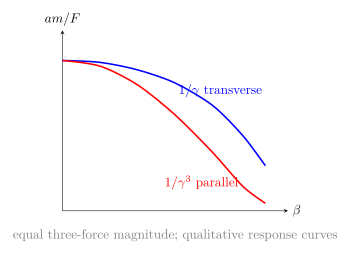
\[\boxed{\mathbf F_{\parallel}=\gamma^3m\mathbf a_{\parallel}}, \qquad \boxed{\mathbf F_{\perp}=\gamma m\mathbf a_{\perp}}.\]
同样大小的 force 在高速时产生的 coordinate acceleration 会受抑制,而且纵向抑制是 \(\gamma^3\)、横向是 \(\gamma\)。这不是引入两种质量,而是 momentum 对 velocity 的非线性响应。
proper acceleration 与均匀加速世界线
proper acceleration 是瞬时共动惯性系中 accelerometer 测得的加速度大小:
\[\alpha=\sqrt{-A^2}.\]
一维恒定 \(\alpha\)、初始 \(t=x=u=0\) 时,用固有时参数化:
\[ct(\tau)=\frac{c^2}{\alpha}\sinh\left(\frac{\alpha\tau}{c}\right),\]
\[x(\tau)=\frac{c^2}{\alpha} \left[\cosh\left(\frac{\alpha\tau}{c}\right)-1\right],\]
\[u(\tau)=c\tanh\left(\frac{\alpha\tau}{c}\right).\]
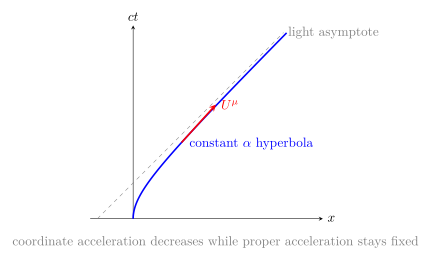
由上式 \(u<c\) 对所有有限 \(\tau\);constant proper acceleration 并不会越过光速。coordinate acceleration 为 \(du/dt=\alpha/\gamma^3\),随速度升高而下降。
Knowledge 2 — Action of a free relativistic particle / 自由相对论粒子的作用量
Knowledge ID: P06-U03-L03-K02
用 Lorentz scalar 构造 action
自由 massive particle 没有优先参考系。最简单的局域 Lorentz scalar worldline functional 是固有时:
\[\boxed{S=-mc^2\int_A^B d\tau} =-mc\int_A^B ds, \qquad ds\equiv c\,d\tau=\sqrt{dx^\mu dx_\mu}.\]
它与 worldline parameter 的重新选择无关,因为 \(d\tau\) 是几何量。固定 timelike 端点 \(A,B\) 后,物理路径使 \(\delta S=0\);在平直时空中得到直线 inertial worldline。
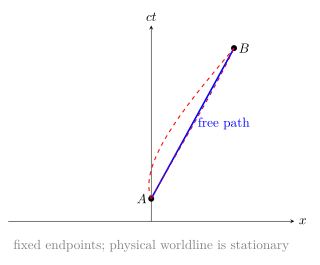
对固定 timelike-separated endpoints,惯性直线积累最大 proper time;因 action 前有负号,它给最小 \(S\)。但在更复杂问题中 action 只保证 stationary,不应把所有变分原理都口语化为“最小作用量”。
以 coordinate time 参数化
由
\[d\tau=dt\sqrt{1-u^2/c^2},\]
写成
\[S=\int L\,dt,\]
\[\boxed{L(\mathbf u)=-mc^2\sqrt{1-\frac{u^2}{c^2}}}.\]
低速展开:
\[L=-mc^2+\frac12mu^2+\frac18m\frac{u^4}{c^2}+\cdots.\]
常数 \(-mc^2\) 不影响固定粒子种类下的 Euler–Lagrange equation;去掉它后,leading term 正是 classical free-particle Lagrangian。
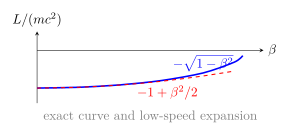
free \(L\) 不显含 \(\mathbf x\),所以 Euler–Lagrange equation 给 canonical momentum 恒定;下一节将证明它正是 \(\gamma m\mathbf u\)。
Knowledge 3 — Relativistic Lagrangian and Hamiltonian / 相对论拉格朗日量与哈密顿量
Knowledge ID: P06-U03-L03-K03
canonical momentum
由自由粒子 Lagrangian:
\[\mathbf p_{can}=\frac{\partial L}{\partial\mathbf u}.\]
分量求导得到
\[\boxed{\mathbf p_{can}=\frac{m\mathbf u}{\sqrt{1-u^2/c^2}} =\gamma m\mathbf u=\mathbf p}.\]
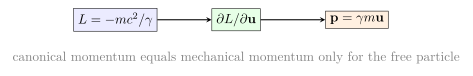
若引入 electromagnetic potential,canonical momentum 与 kinetic/mechanical momentum 会不同;因此此等号不能无条件搬到下一 Unit。
Legendre transform 与 Hamiltonian
定义
\[H=\mathbf p\mathbin{\cdot}\mathbf u-L.\]
代入 \(\mathbf p=\gamma m\mathbf u\) 与 \(L=-mc^2/\gamma\):
\[H=\gamma mu^2+\frac{mc^2}{\gamma} =\gamma mc^2.\]
再消去 \(\mathbf u\):
\[\boxed{H(\mathbf p)=\sqrt{p^2c^2+m^2c^4}=E}.\]
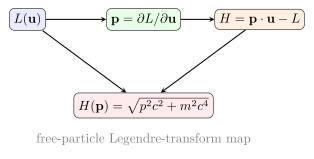
Hamilton equation 恢复速度:
\[\dot{\mathbf x}=\frac{\partial H}{\partial\mathbf p} =\frac{c^2\mathbf p}{E}=\mathbf u.\]
free \(H\) 不含 \(\mathbf x\),故
\[\dot{\mathbf p}=-\frac{\partial H}{\partial\mathbf x}=0.\]
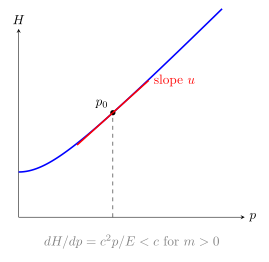
action、Lagrangian 与 Hamiltonian 的边界
这三个形式给同一 free massive dynamics,但各有优势:action 显示 Lorentz invariance 与 worldline geometry;\(L(\mathbf x,\mathbf u,t)\) 适合变分与对称性;\(H(\mathbf x,\mathbf p,t)\) 适合相空间和能量演化。不能因三个公式形式不同就把 \(L\)、\(H\)、\(E\) 当作同一个量;本课恰好有 free \(H=E\)。
Knowledge 4 — Massless-particle kinematics / 无质量粒子运动学
Knowledge ID: P06-U03-L03-K04
null four-momentum 与速度
massless on-shell particle 满足
\[p^\mu p_\mu=0,\]
\[\boxed{E=pc}, \qquad \boxed{\mathbf p=\frac{E}{c}\hat{\mathbf n}}.\]
由 massless Hamiltonian
\[H(\mathbf p)=c\lvert\mathbf p\rvert\]
得到
\[\dot{\mathbf x}=\frac{\partial H}{\partial\mathbf p} =c\frac{\mathbf p}{\lvert\mathbf p\rvert} =c\hat{\mathbf n}.\]
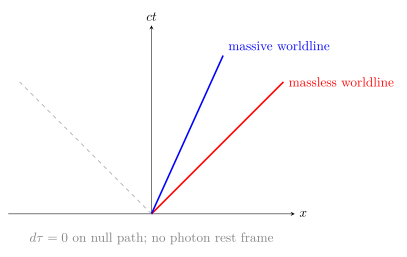
单个 massless particle 没有 rest frame,也没有按 proper time 定义的 \(U^\mu\)。因此 \(p^\mu=mU^\mu\) 不能通过“令 \(m=0\)、\(U\to\infty\)”作为定义;应直接以非零 null four-momentum 描述。
massive 与 massless dispersion
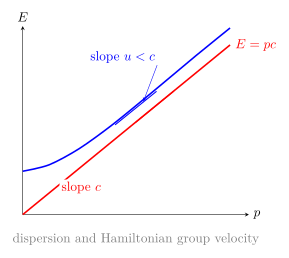
对于单个 photon,boost 可改变 \(E\) 与传播方向,却不能使 \(E'=0\);任何 subluminal boost 都不能追上 null worldline。两个或更多 massless particles 的总四动量则可 timelike,并存在系统 CM frame。
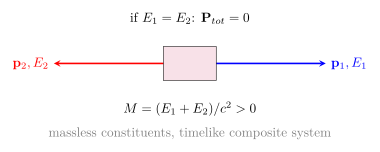
massless action 的模型边界
massive action \(-mc^2\int d\tau\) 在 \(m=0\) 且 \(d\tau=0\) 时退化为零,不能产生 null equation of motion。更高级处理中可引入 affine parameter \(\lambda\) 与 auxiliary field \(e(\lambda)\):
\[S=\frac12\int d\lambda\,e^{-1}\dot x^\mu\dot x_\mu.\]
对 \(e\) 变分给 null constraint \(\dot x^2=0\)。本课只用这个事实说明“massless limit 的 action 需重新参数化”,不展开 constrained Hamiltonian theory。
Worked Examples / 完整例题
Worked Example 1 — Parallel and perpendicular force response
质量 \(m=2.00\,\mathrm{kg}\) 的粒子以 \(u=0.800c\) 沿 \(+x\) 运动。分别施加大小 \(10.0\,\mathrm N\) 的平行力与垂直力,求瞬时 coordinate acceleration。
研究对象: 单个恒定 invariant-mass 粒子。
系统/参考系: 给定 inertial lab 的瞬时量。
坐标与正方向: \(\mathbf u\parallel+x\);平行情形 \(\mathbf F\parallel+x\),垂直情形 \(\mathbf F\parallel+y\)。
模型: \(\mathbf F=d\mathbf p/dt\),忽略辐射和质量变化。
\[\gamma=\frac1{\sqrt{1-0.800^2}}=1.667.\]
平行时
\[a_{\parallel}=\frac{F_{\parallel}}{\gamma^3m} =\frac{10.0}{(1.667)^3(2.00)} =1.08\,\mathrm{m\,s^{-2}}.\]
垂直时
\[a_{\perp}=\frac{F_{\perp}}{\gamma m} =\frac{10.0}{(1.667)(2.00)} =3.00\,\mathrm{m\,s^{-2}}.\]
检查: 两者均在同一 lab 比较;高速纵向响应更受抑制。\(u\to0\) 时两式都回到 \(F/m=5.00\,\mathrm{m\,s^{-2}}\)。三位有效数字。
Worked Example 2 — Constructing and checking a four-force
粒子在 \(S\) 中以 \(\mathbf u=0.600c\hat{\mathbf x}\) 运动,three-force 为 \(\mathbf F=(4.00\hat{\mathbf x}+3.00\hat{\mathbf y})\,\mathrm N\)。求 \(K^\mu\) 并验证 \(K\cdot U=0\)。
研究对象: 恒定 invariant-mass 粒子。
系统/参考系: 瞬时 inertial frame \(S\)。
坐标与正方向: 如分量定义。
模型: \(K^\mu=\gamma(\mathbf F\cdot\mathbf u/c,\mathbf F)\),度规 \(+---\)。
\[\gamma=1.250, \qquad \frac{\mathbf F\cdot\mathbf u}{c}=(4.00)(0.600)=2.40\,\mathrm N.\]
所以
\[K^\mu=(3.00,5.00,3.75,0)\,\mathrm N.\]
而
\[\frac{U^\mu}{c}=(1.250,0.750,0,0).\]
\[\frac{K\cdot U}{c} =(3.00)(1.250)-(5.00)(0.750)=0.\]
检查: \(K^0\) 单位是 N,因为 \(E/c\) 对固有时求导也是力单位;垂直 force 分量不做瞬时功,但仍出现在空间四力中。
Worked Example 3 — One year of constant proper acceleration
飞船从静止开始沿 \(+x\) 保持 proper acceleration \(\alpha=9.81\,\mathrm{m\,s^{-2}}\)。船上经过 \(\tau=1.00\,\mathrm{yr}\) 后,求 rapidity、lab speed、lab elapsed time 和 lab displacement。取 \(1\,\mathrm{yr}=365.25\,\mathrm d\)。
研究对象: 理想点状飞船。
系统/参考系: 平直时空中的初始 inertial lab;船上时间为 proper time。
坐标与正方向: 初始 \(x=t=0\),加速沿 \(+x\)。
模型: 一维 constant proper acceleration;忽略转弯、有限尺寸和燃料。
定义 rapidity
\[\chi=\frac{\alpha\tau}{c}=1.033.\]
\[\beta=\tanh\chi=0.775, \qquad \gamma=\cosh\chi=1.582.\]
\[t=\frac{c}{\alpha}\sinh\chi =1.187\,\mathrm{yr}.\]
\[x=\frac{c^2}{\alpha}(\cosh\chi-1) =5.33\times10^{15}\,\mathrm m =0.564\,\mathrm{ly}.\]
检查: \(u=0.775c<c\);lab time 大于 proper time;低 \(\chi\) 时 \(x\approx\alpha\tau^2/2\)。三位有效数字。
Worked Example 4 — Lagrangian, canonical momentum, Hamiltonian and massless limit
某 free particle 的 rest energy 为 \(mc^2=1.00\,\mathrm{GeV}\),在给定 frame 中 \(u=0.600c\)。求 \(L\)、\(pc\)、\(H\),验证 Legendre transform,并说明固定 \(p\) 下 \(m\to0\) 的极限。
研究对象: 单个 free on-shell particle。
系统/参考系: 给定 inertial frame;无势能。
坐标与方向: 一维运动,取 \(+x\)。
模型: \(L=-mc^2/\gamma\),\(H=pu-L\)。
\[\gamma=1.250.\]
\[L=-\frac{mc^2}{\gamma}=-0.800\,\mathrm{GeV}.\]
\[pc=\gamma\beta mc^2=(1.250)(0.600)(1.00) =0.750\,\mathrm{GeV}.\]
\[pu=(pc)\beta=(0.750)(0.600)=0.450\,\mathrm{GeV}.\]
\[H=pu-L=0.450-(-0.800)=1.250\,\mathrm{GeV} =\gamma mc^2.\]
质量壳也给
\[H=\sqrt{(pc)^2+(mc^2)^2} =\sqrt{0.750^2+1.00^2}=1.250\,\mathrm{GeV}.\]
固定非零 \(p\) 令 \(m\to0\):\(H\to pc\),\(u=\partial H/\partial p\to c\)。
检查: \(L\) 可为负且不是 energy;\(H\) 才等于 free-particle total energy。所有列出的 GeV 量都是能量,\(p\) 本身为 \(0.750\,\mathrm{GeV}/c\)。
Lesson synthesis / 本课综合
- 动力学从 \(p^\mu\) 开始:\(K^\mu=dp^\mu/d\tau\) 保证 energy rate 与 three-force 自动组成四矢量。
- \(K\cdot U=0\) 与 \(U^2=c^2\) 相容;平行和横向 coordinate acceleration 分别受 \(\gamma^3\)、\(\gamma\) 抑制。
- free massive action 取 worldline proper time,故 Lorentz invariant;用 \(t\) 参数化后得到相对论 Lagrangian。
- Legendre transform 给 canonical momentum \(\gamma m\mathbf u\) 与 Hamiltonian mass shell。
- massless kinematics 是 null mass shell;它是 \(H\) 的平滑固定动量极限,却不是 proper-time action 的直接 \(m=0\) 代入。
Formula-and-decision table / 公式与决策表
| Need | Formula | Conditions | Main caution |
|---|---|---|---|
| three-force | \(\mathbf F=d\mathbf p/dt\) | stated inertial frame | generally not \(m\mathbf a\) |
| four-force | \(K^\mu=dp^\mu/d\tau=\gamma(\mathbf F\cdot\mathbf u/c,\mathbf F)\) | invariant mass fixed | \(K\cdot U=0\) |
| acceleration response | \(F_\parallel=\gamma^3ma_\parallel\), \(F_\perp=\gamma ma_\perp\) | instantaneous decomposition | components refer to same frame |
| proper acceleration | \(\alpha=\sqrt{-A^2}\) | timelike worldline | differs from lab \(d\mathbf u/dt\) |
| free action | \(S=-mc^2\int d\tau\) | massive free particle | stationary, parameter-independent |
| free Lagrangian | \(L=-mc^2\sqrt{1-u^2/c^2}\) | coordinate-time parameterization | not equal to energy |
| canonical momentum | \(\partial L/\partial\mathbf u=\gamma m\mathbf u\) | free particle | with fields, canonical and mechanical may differ |
| Hamiltonian | \(H=\sqrt{p^2c^2+m^2c^4}\) | free positive-energy branch | \(\partial H/\partial\mathbf p=\mathbf u\) |
| massless kinematics | \(p^2=0\), \(H=pc\), \(u=c\) | nonzero null four-momentum | no proper-time four-velocity/rest frame |
Model boundaries / 模型边界
- \(K^\mu=mA^\mu\) 假设单粒子 invariant mass 恒定;吸收、喷射或复合系统质量改变时需更完整的四动量流描述。
- \(\mathbf F_\parallel=\gamma^3m\mathbf a_\parallel\) 和横向公式是某一瞬时 inertial frame 的分解,不是独立 Lorentz scalars。
- constant proper acceleration worldline 是理想点粒子模型;有限飞船保持 Born rigidity 需要不同位置有不同 proper acceleration。
- \(S=-mc^2\int d\tau\) 只描述 free massive point particle;外场耦合必须增加 Lorentz-scalar interaction term。
- canonical momentum 等于 mechanical momentum 仅对本课 free \(L\) 成立;电磁场中二者相差与 vector potential 有关。
- classical massless point-particle kinematics 不包含 photon polarization、quantization、creation/annihilation 或 wave-packet dispersion。
Misconception clinic / 误区诊所
- “相对论里牛顿第二定律失效,所以不能写力。” 可精确定义 \(\mathbf F=d\mathbf p/dt\);失效的是普遍写成 \(m\mathbf a\)。
- “四力与四速度正交,所以三维力永远垂直三维速度。” Minkowski orthogonality 含时间分量;纵向 three-force 完全允许并做功。
- “constant acceleration 意味着 lab 中 \(du/dt\) 恒定。” constant proper acceleration 时 \(du/dt=\alpha/\gamma^3\),随速度下降。
- “Lagrangian 就是 total energy。” 本课 \(L=-mc^2/\gamma\),而 \(H=\gamma mc^2=E\);二者经 Legendre transform 相连。
- “把 \(m=0\) 代入 \(-mc^2\int d\tau\) 就得到 photon action。” 该式退化为零;null path 需 affine parameter/constraint formulation。
Practice and retrieval / 练习与提取
- K01: 证明 \(dE/dt=\mathbf F\cdot\mathbf u\) 可由 \(E^2=p^2c^2+m^2c^4\) 与 \(\mathbf F=d\mathbf p/dt\) 得到。
Answer
对时间求导: \[2E\frac{dE}{dt}=2c^2\mathbf p\cdot\frac{d\mathbf p}{dt}.\] 因 \(c^2\mathbf p/E=\mathbf u\),故 \(dE/dt=\mathbf u\cdot\mathbf F\)。
- K01: 若 \(\mathbf F\perp\mathbf u\),瞬时 \(K^0\) 是多少?粒子能量是否改变?
Answer
\(\mathbf F\cdot\mathbf u=0\),故 \(K^0=0\) 且瞬时 \(dE/dt=0\);动量方向仍可改变。
- K01: \(u=0.600c\) 时,同样大小的平行和垂直 three-force 产生的 \(a_\perp/a_\parallel\) 是多少?
Answer
\(a_\perp=F/(\gamma m)\)、\(a_\parallel=F/(\gamma^3m)\),所以 \[\frac{a_\perp}{a_\parallel}=\gamma^2=1.25^2=1.5625.\]
- K02: 为什么 free action 用 \(\int d\tau\) 而不是 \(\int dt\) 最直接体现 Lorentz invariance?
Answer
\(d\tau\) 是沿 worldline 的 Lorentz scalar;单独的 coordinate time \(dt\) 随 frame 改变。用 \(t\) 参数化后,补偿这种变化的因子正是 \(\sqrt{1-u^2/c^2}\)。
- K02: 展开 \(L=-mc^2\sqrt{1-u^2/c^2}\) 到 \(u^4\) 阶。
Answer
用 \(\sqrt{1-z}=1-z/2-z^2/8+\cdots\): \[L=-mc^2+\frac12mu^2+\frac18m\frac{u^4}{c^2}+O(u^6/c^4).\]
- K03: 从 \(H=\sqrt{p^2c^2+m^2c^4}\) 求 \(\partial H/\partial\mathbf p\)。
Answer
\[\frac{\partial H}{\partial\mathbf p} =\frac{c^2\mathbf p}{H} =\frac{c^2\mathbf p}{E}=\mathbf u.\]
- K03: 为什么 \(H\) 的 positive square root branch 合适?
Answer
本课描述经典正能粒子,静止时应有 \(H=+mc^2\),并连续连接低速能量;负能 branch 不属于此单粒子经典模型。
- K04: 单 photon 能否通过有限 Lorentz boost 变到 \(\mathbf p'=0\)?
Answer
不能。若 \(\mathbf p'=0\),null mass shell 要求 \(E'=0\),即零四矢量;可逆 Lorentz transformation 不会把非零四矢量变成零。
- K04: massless Hamiltonian \(H=pc\) 的 group velocity 是多少?
Answer
\[\mathbf u=\frac{\partial H}{\partial\mathbf p} =c\frac{\mathbf p}{p},\] 大小恒为 \(c\),方向沿 momentum。
- 综合: 两个能量相等、反向传播的 photon 是否各有 rest frame?系统是否有 CM frame?
Answer
单 photon 各自没有 rest frame;两者总三动量为零,所以该二 photon 系统所在 frame 就是 CM,且总四动量 timelike、系统 invariant mass 为 \(2E/c^2\)。
Exit ticket / 离堂检核
- 从 \(K^\mu=dp^\mu/d\tau\) 推出其时间与空间分量,并用 \(K\cdot U=0\) 检查 \(c\) 因子。
- 用 action → Lagrangian → canonical momentum → Hamiltonian 的链条说明为何 free-particle dispersion 与速度上限同时出现。
References and source notes / 参考资料与来源说明
Source-to-content map
| Source | Used for | Knowledge ID / section | Model boundary or convention |
|---|---|---|---|
| MIT OCW 8.033 (2024), Lecture 13: Accelerations and Forces | four-acceleration, four-force, proper acceleration | K01 | source notation translated to \(+---\) and this lesson's \(K^\mu\) |
| MIT OCW 8.033 (2024), Lecture 16: Calculus of Variations and Motion in Spacetime | stationary proper-time principle and free worldlines | K02 | distinguishes maximum proper time from generic stationary action |
| Stony Brook MAT 560 Lecture Notes, Ch. 15 Relativistic Particle | free action, Lagrangian, canonical momentum, energy and Hamiltonian | K02–K03 | source convention checked and converted; SI factors retained |
| Rutgers, Introduction to Relativistic Particle Mechanics | reparameterized action and Euler–Lagrange structure | K02–K03 | advanced caveats on scalar interactions treated only as boundary |
| UT Austin, Relativistic Energy and Momentum | three-force/acceleration relation, energy and momentum dynamics | K01, K03 | invariant mass terminology used instead of velocity-dependent mass |
| University of Maryland PHYS 606, Relativistic Mechanics and Maxwell's Equations | covariant particle action and electromagnetic interface | K02–K04, review hooks | next-unit coupling not developed here |
资料与 URL 实际打开核对日期:2026-08-29。推导、数值与图示均按本课约定独立完成;图未复制教材。
复习与拓展
- Four-Vectors:四速度 norm 与 boost convention。
- Energy, Momentum, and Reactions:mass shell、系统 invariant mass 与 massless composite systems。
- Electric and Magnetic Fields Across Frames:\(K^\mu=qF^{\mu\nu}U_\nu\)、canonical momentum 与 vector potential。
- Equivalence and Curved Spacetime:free-particle action 在 curved metric 中推广为 geodesic action。